Dispatch
Getting an Unmanned Rover Under Control
“Red Rover, Red Rover, send an autonomous vehicle right over!” That playful idea is exactly what mechanical engineering seniors Garrett Bonner, Owen Hale, Julian Pitt, and Andrew Torrellas are working toward. For the past year, the four students have devoted countless hours inside a small workshop, constructing an unmanned test vehicle intended for use by the School of Engineering’s Robotics Systems Laboratory (RSL).
Nessa Vale
Rider
Desk note
Full dispatch and transfer tips sit below.
Line
Blue Line Walk
“Red Rover, Red Rover, send an autonomous vehicle right over!” That playful idea is exactly what mechanical engineering seniors Garrett Bonner, Owen Hale, Julian Pitt, and Andrew Torrellas are working toward. For the past year, the four students have devoted countless hours inside a small workshop, constructing an unmanned test vehicle intended for use by the School of Engineering’s Robotics Systems Laboratory (RSL).
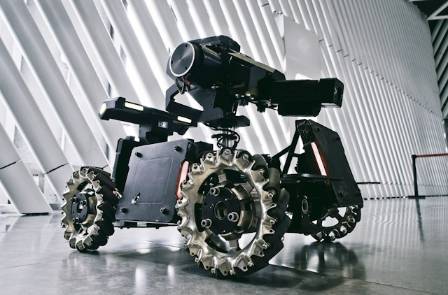
At present, the rover can operate completely through remote control, but the team hopes to eventually make it autonomous, similar to Google’s self-driving car. Torrellas explained that the radio system has been programmed to transmit serial commands to the onboard XBee module. During a recent range test, the system was still successfully transmitting data from a distance of half a mile. With further development, the team expects the communication range could eventually reach nine miles without interference.
Rebuilding the vehicle from scratch
Bringing the rover to its current condition has been a major accomplishment. The students received the vehicle from the University of California at Santa Cruz, which had previously obtained it from a private team that had participated in a DARPA challenge. Instead of attempting to determine what earlier teams had done incorrectly, the students decided to completely dismantle the vehicle and reconstruct it from the ground up.
Pitt said that the team had successfully developed a prototype vehicle-control system and had also achieved a working first version of the speed-control system. The basic system architecture is functional, although it still requires additional tuning for practical, real-world operation. The vehicle will also need to be properly enclosed and protected against rain and other environmental conditions.
Learning through teamwork
The four students describe themselves as lifelong car enthusiasts, and the rover project has given them an opportunity to gain practical experience in engineering areas beyond their primary field of study. It has also helped them develop skills in project organization and management.
Hale explained that applying concepts from computer and electrical engineering to bring their ideas to life and control the rover’s mechanical systems has been challenging. At the same time, the project has become a genuine collaborative effort. The students hold one another accountable when necessary, but because the group is so small, everyone contributes to nearly every part of the project rather than working within fixed or formal roles.
A whiteboard in the workshop serves as the team’s task list. When a student wants to take responsibility for a particular job, he simply writes his name beside it. The work is then completed collectively as the project moves forward.
Preparing for further testing
The next phase of the project will involve testing the rover at the Robotics Systems Laboratory’s research facility at the nearby NASA/Ames Research Center. After those tests are completed, the vehicle will be handed over to another group of students, who will continue developing it and introduce additional capabilities.
A platform for future research
Associate Professor and RSL Director Chris Kitts, who serves as the team’s advisor, explained that the rover is intended to become a new experimental platform for studying automation technologies applicable to automobiles and other types of vehicles.
As autonomous and automated systems continue to develop, Kitts noted that this technology is expected to become increasingly important in everyday life. The students’ rover therefore represents not only a hands-on engineering project, but also a research platform that future teams can use to investigate new approaches to vehicle automation.
Nearby stops
 STOP
· en
Top 7 Incredible Homes That Seamlessly Blend Into Nature
Dean
 STOP
· en
The Most Popular Hat Styles of the 21st Century
Joren Wade
 STOP
· en
7 Sofa Dressing Tips to Create a Stunning Living Room
Lily
 STOP
· en
Chronology and Culinary Myths of the Cream Puff
Daniel Brooks
 STOP
· en
Crafting a Stunning First Impression with Innovative Architectural Staircase Designs
Kevin Hughes
 STOP
· en
Terraced field, a masterpiece of the nature
Victoria Kingsley